
ROBOT DESIGN
Two robots. One master program.
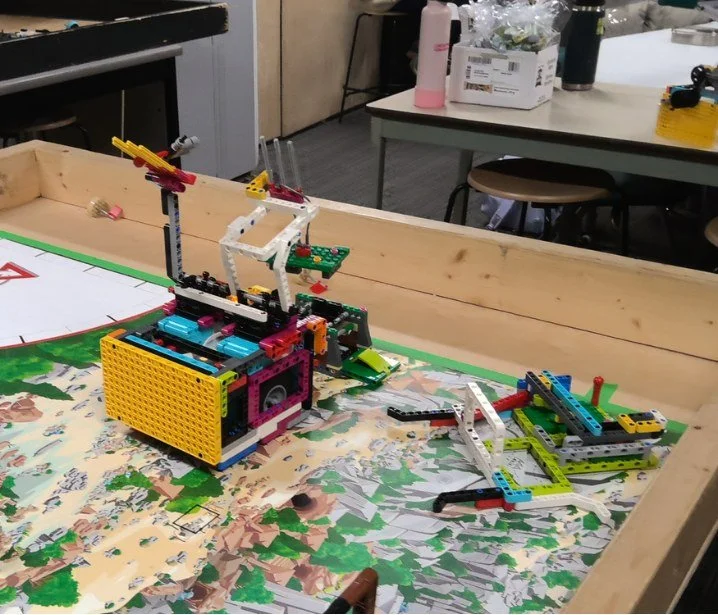
We chose missions that were close to home base, had max points, and were easy to complete. Applying these strategies, we have a grand total of 490 points.
ROBOT GAME TOTAL
490 points
Our planned score across all of our runs this season.
HOW WE PICKED MISSIONS
Close, valuable, reliable
Close to home base
Maximum points
Easy and reliable to complete
WHY TWO ROBOTS
Noodle and Toodle
Two robots meant everyone developed building and coding skills, and it doubled our productivity: we could work on both sides of the board at once.
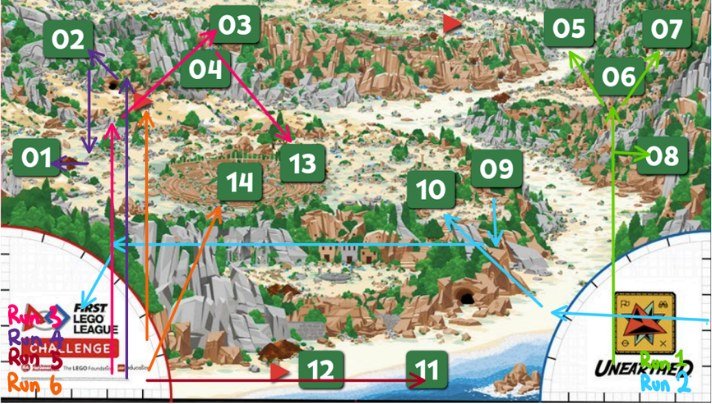
Our run map
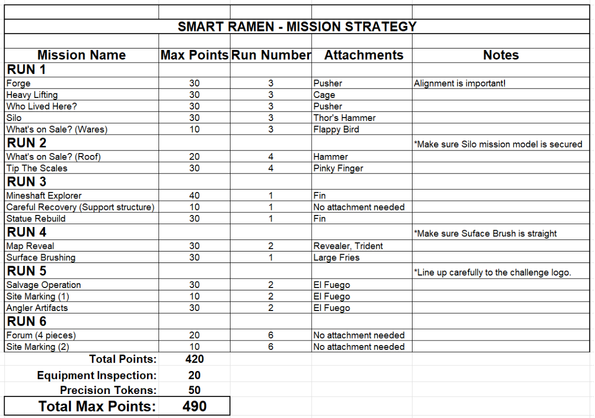
Mission strategy: 490 total max points
Meet Noodle and Toodle
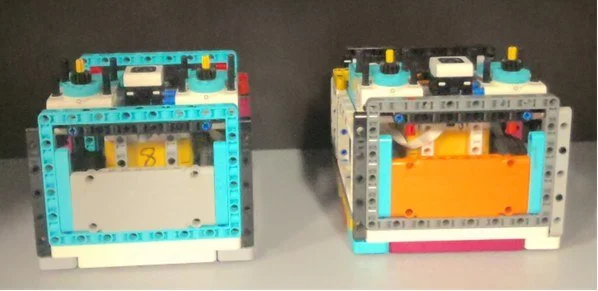
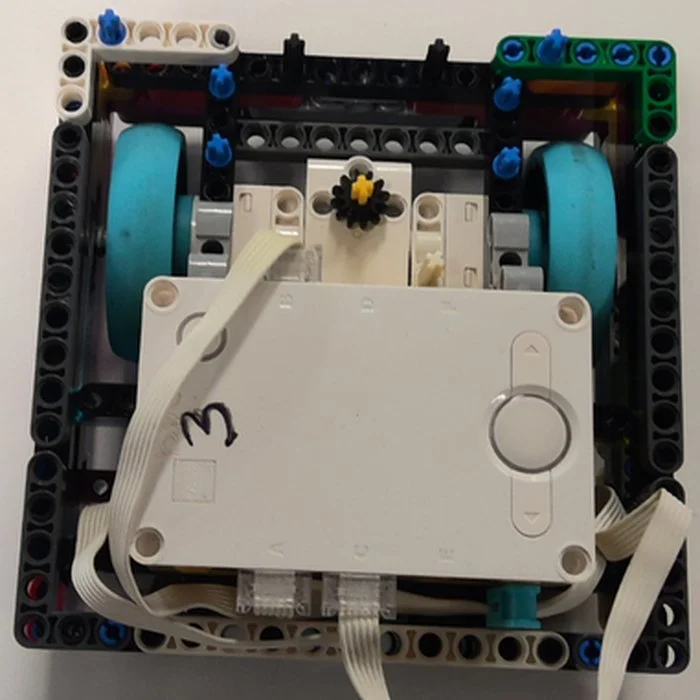
Both robots share the same core design:
MOTORS
4 large motors
2 large drive motors and 2 large accessory motors.
WHEELS AND GYRO
64.2 mm flat tread wheels
Flat tread wheels from the Netherlands for better grip, plus a gyro sensor that makes driving more accurate.
ONE MASTER PROGRAM
Upward-facing color sensor
The color sensor reads the attachment to select the run, so we only need one master program.
Our 12 attachments
Each attachment is built for specific missions.
20 POINTS
Plow
Mission 2: Map Reveal (leave-behind attachment)
20 POINTS
Large Fries
Mission 1: Surface Brushing
10 POINTS
Trident
Mission 2: Map Reveal, lifting the topsoil sections
30 POINTS
Long Arm
Mission 7: Heavy Lifting
30 POINTS
Thor’s Hammer
Mission 12: Salvage Operation, placing the flag
40 POINTS
Gear Box
Mission 11: Angler Artifacts
40 POINTS
Pinky
Missions 9 and 10
30 POINTS
Little Arm
Mission 8: Silo
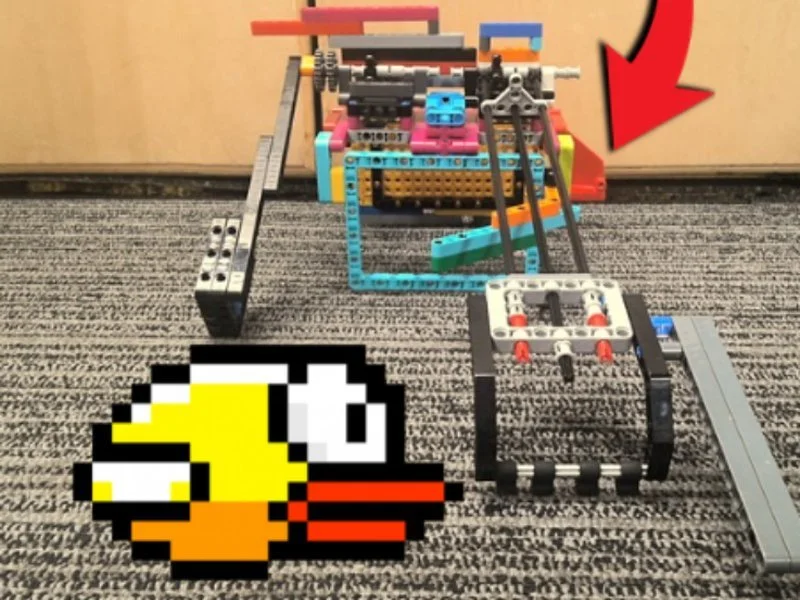
10 POINTS
Flappy Bird
Mission 9: Wares
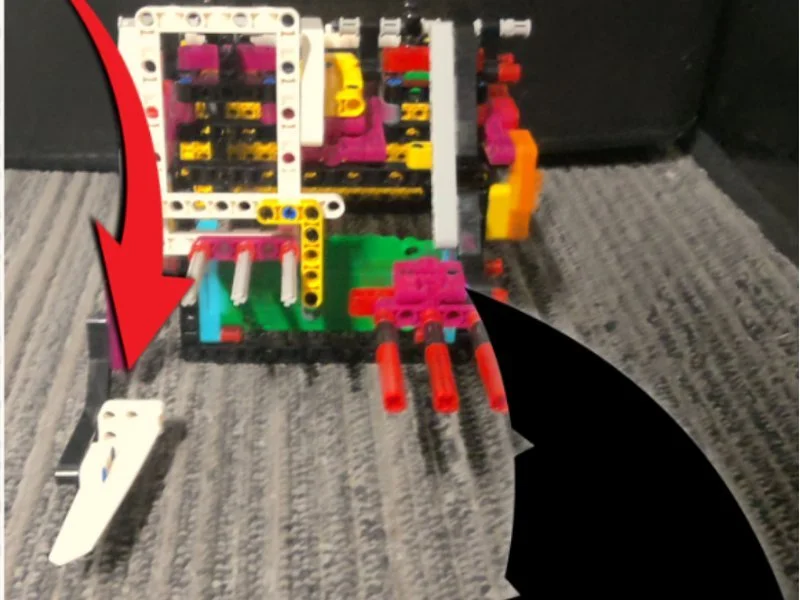
60 POINTS
Fin
Mission 3: Mineshaft Explorer and Mission 13: Statue Rebuild
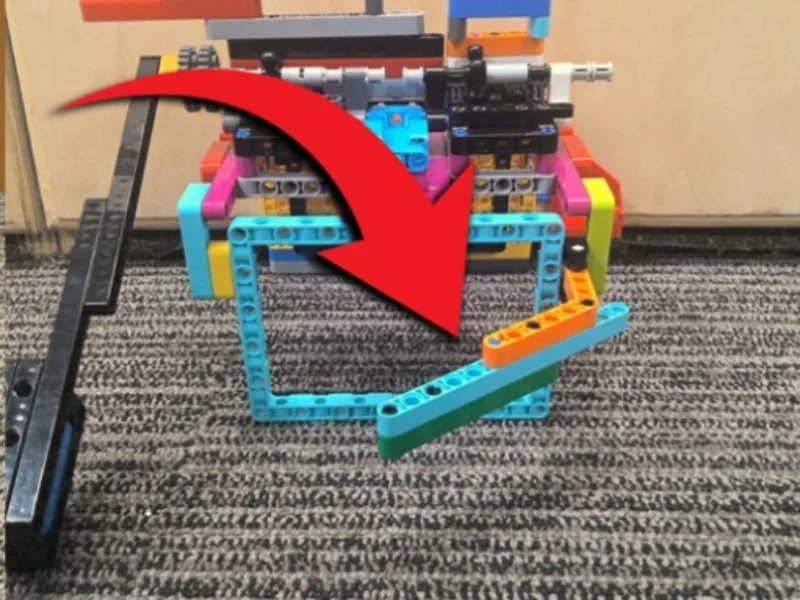
60 POINTS
Pusher
Mission 5: Who Lived Here? and Mission 6: Forge
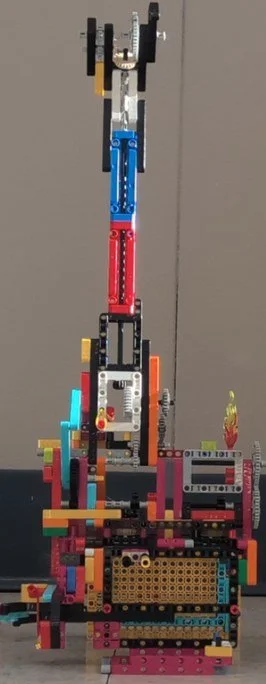
70 POINTS
El Fuego
Missions 11, 12 and 15: Angler Artifacts, Salvage Operation and Site Marking
How our robots improved
We iterated on our robots through continuous testing, trial and error, and adjustments.
ITERATION
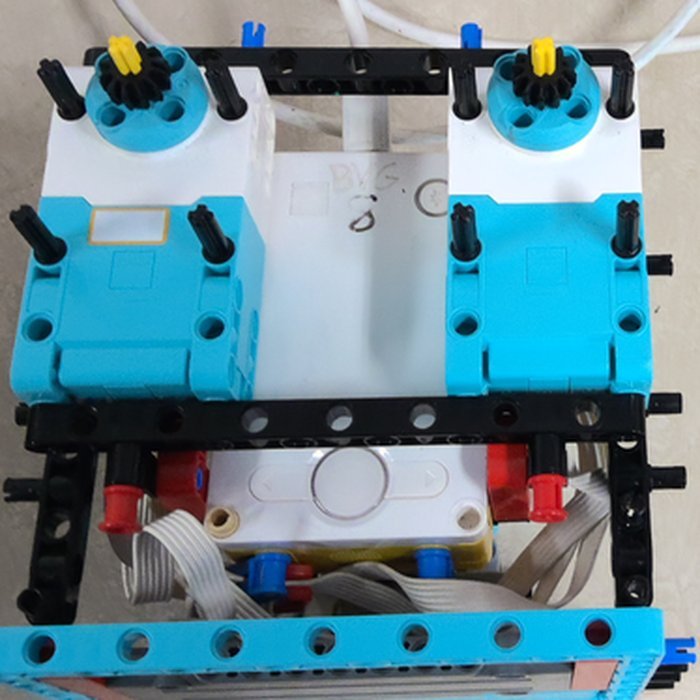
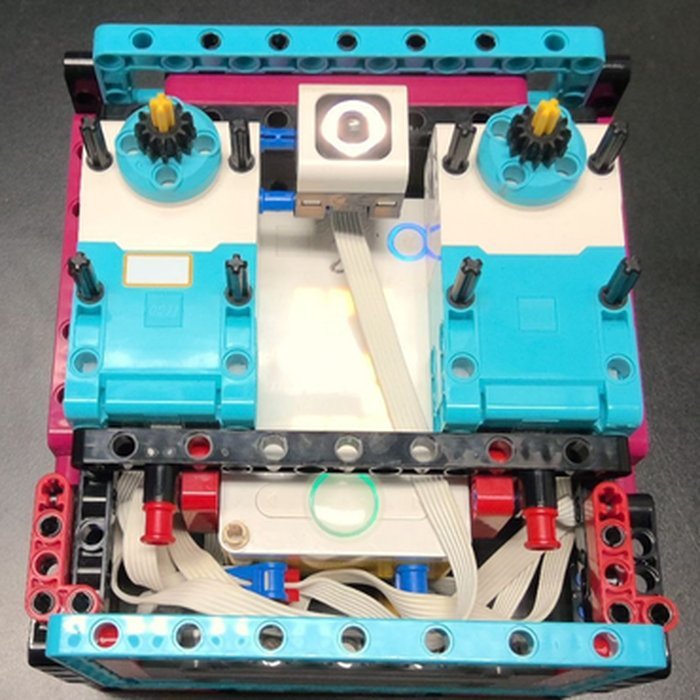
Added a color sensor
We went from no color sensor to an upward-facing one. Now the robot reads the attachment color and picks the right run.
ITERATION
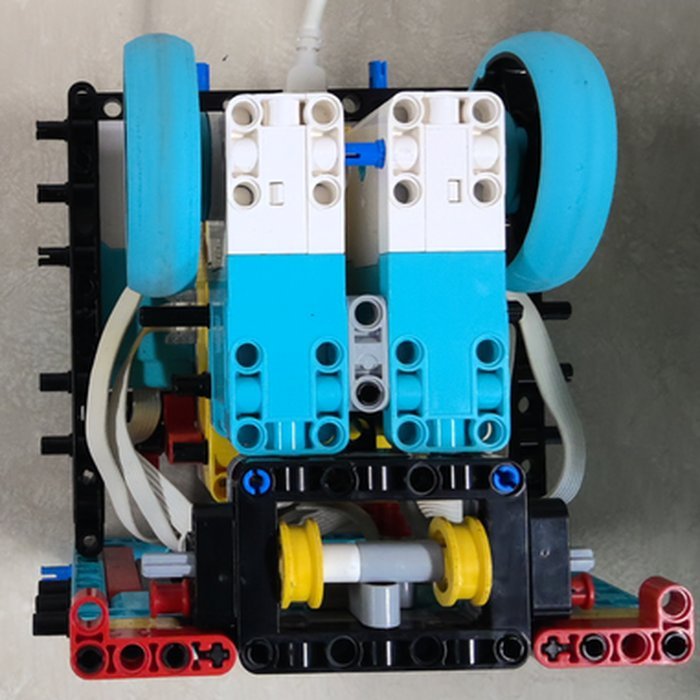
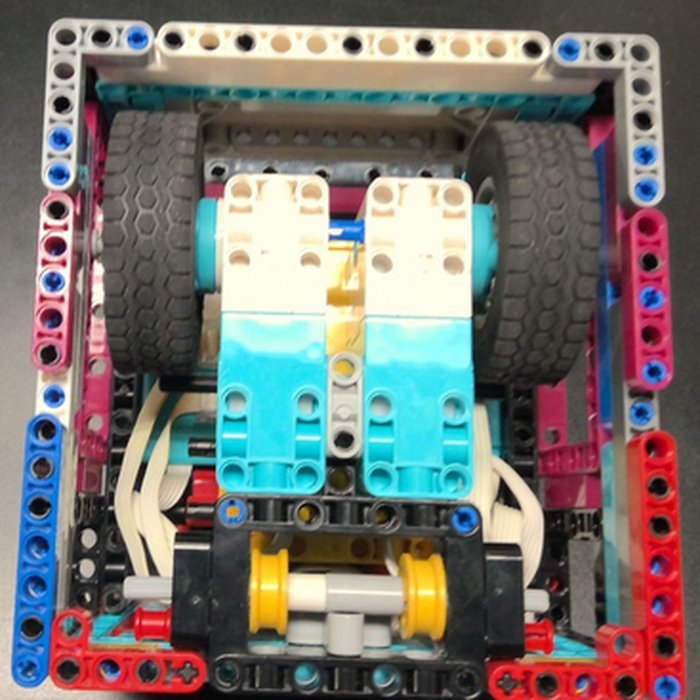
New wheels
We switched from blue wheels to flat tread grip wheels.
ITERATION
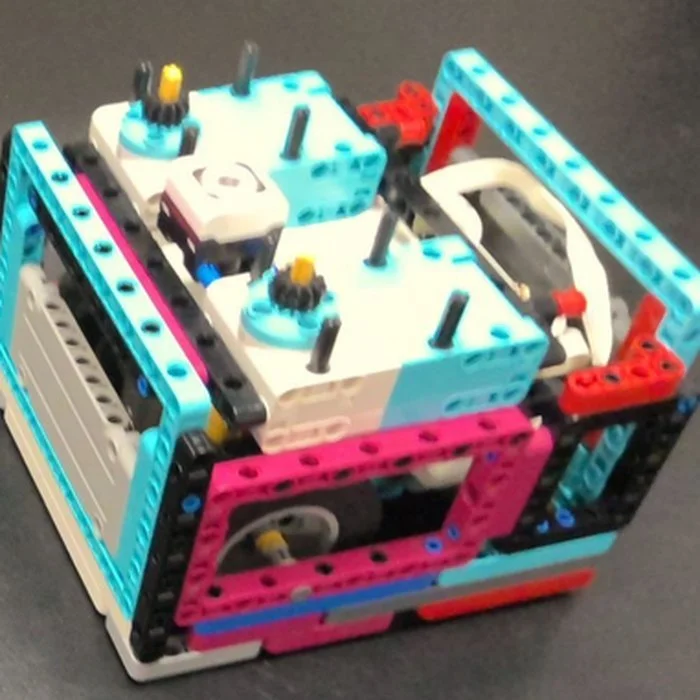
A new robot
We rebuilt our original robot into a new one based on what our testing showed.